Bow Thruster Display
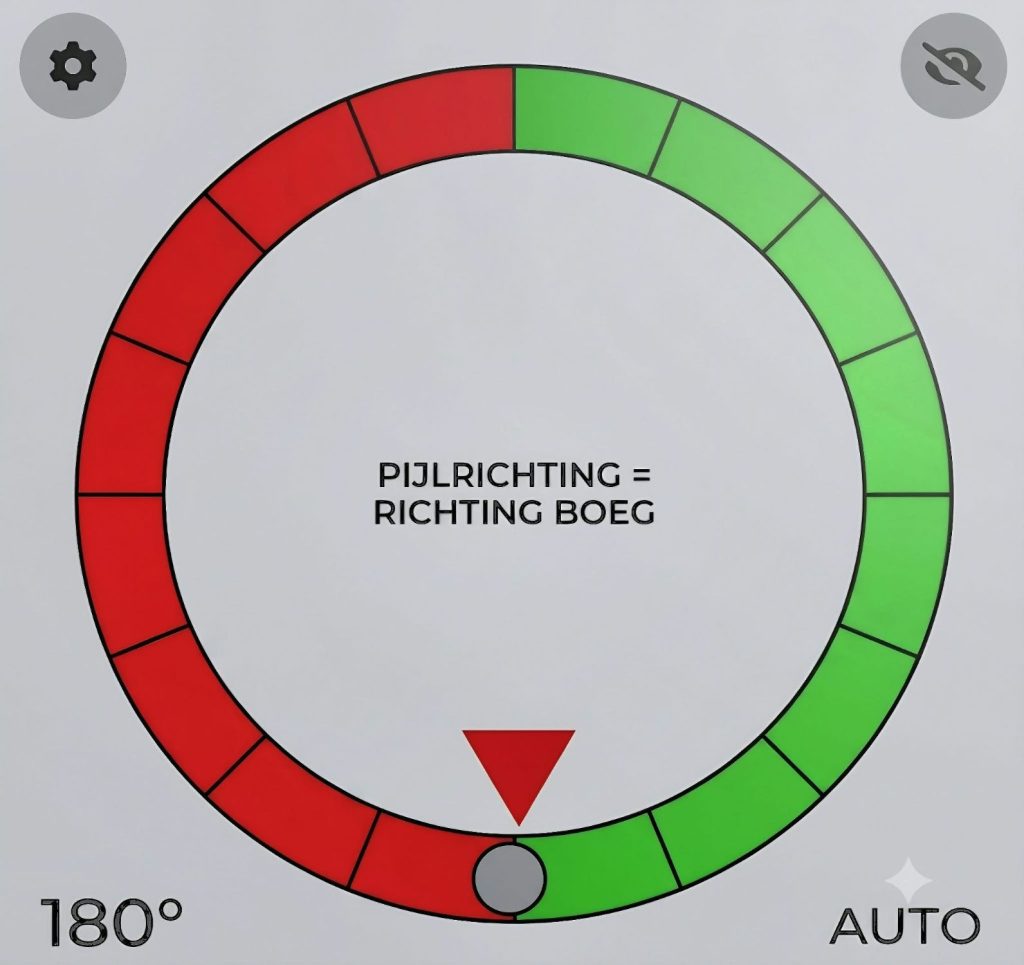
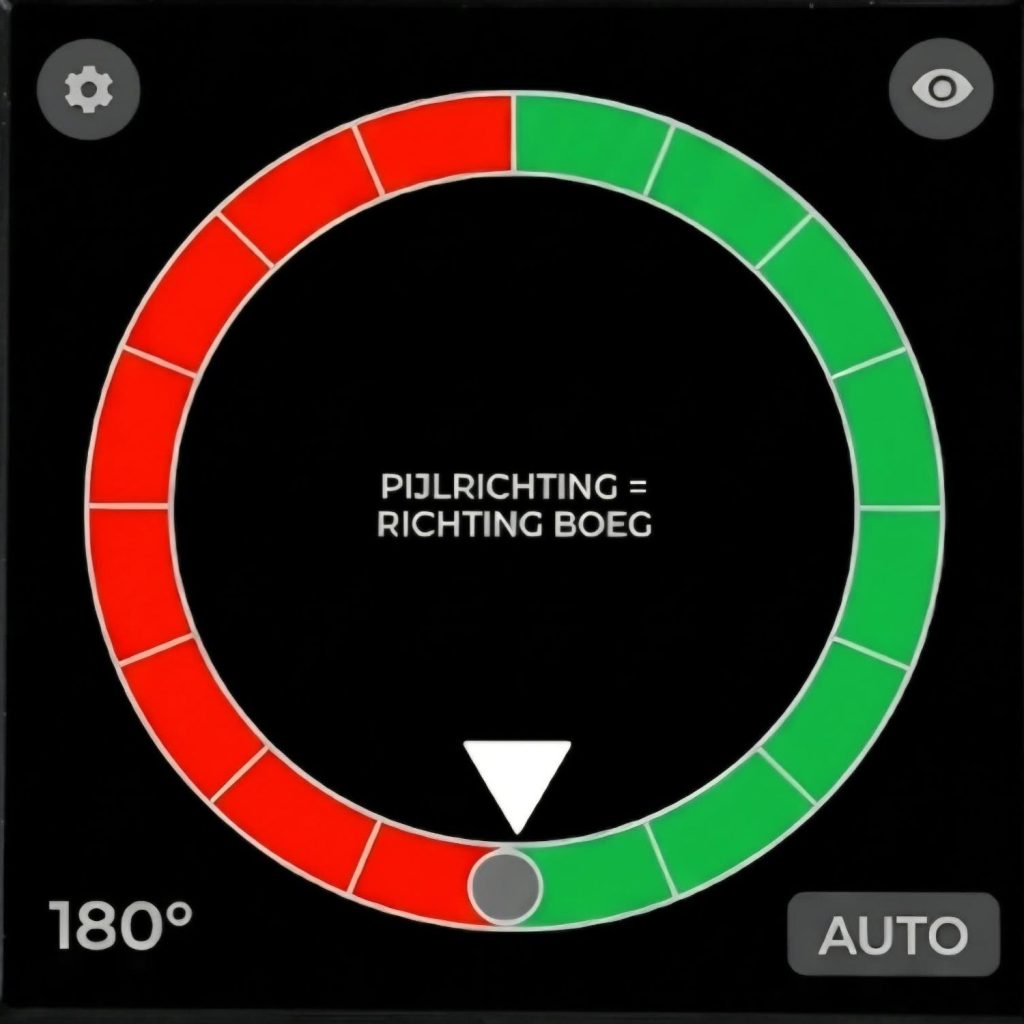
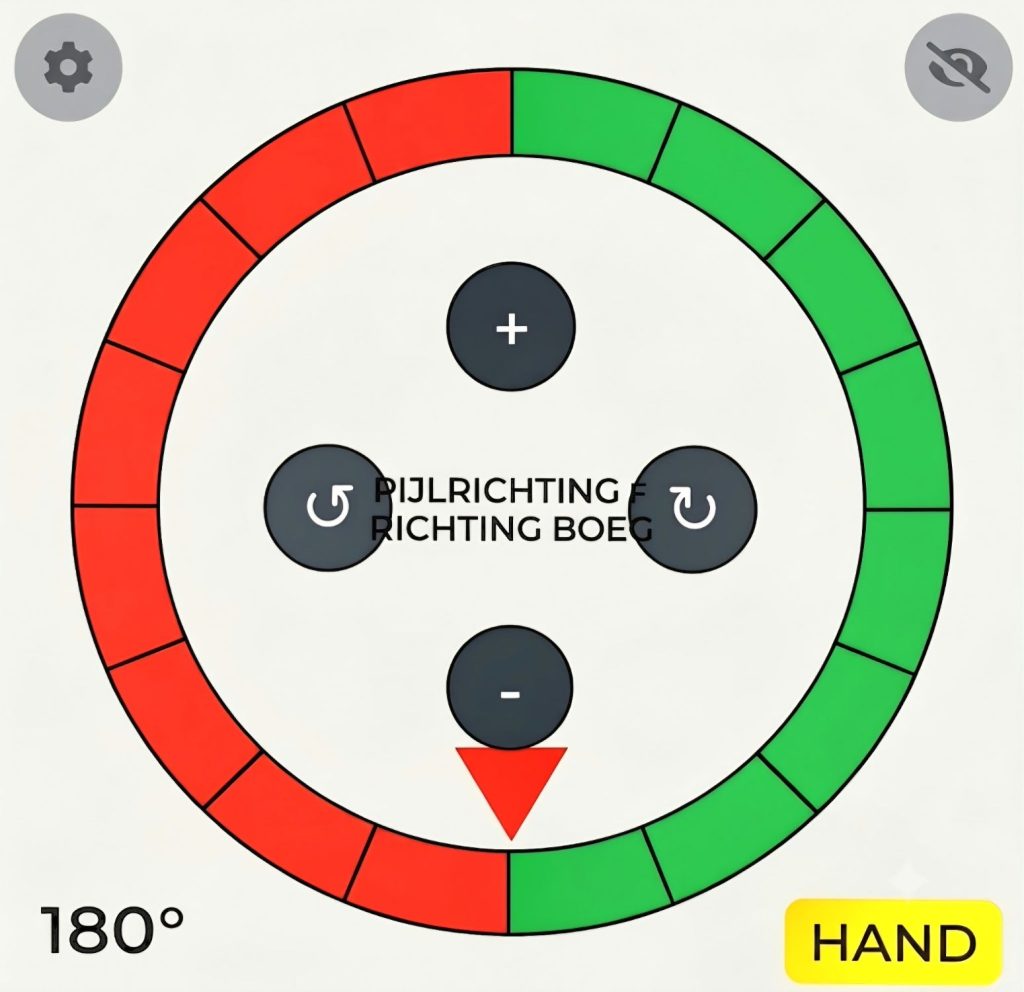
Custom-designed 4″ display unit based on the ESP32-S3, indicating and controlling the direction (follow-up) of the bow thruster on board an inland waterway vessel. The system gives the captain immediate visual feedback on the actual and requested vessel heading.
The unit communicates over CAN bus (TWAI, 100 kbps) with two encoders. One encoder reports the position of the rudder, while the other provides the requested bow direction. The hydraulic steering valves are driven through a CAN relay board. The status of both the encoders and the relay board is monitored. Follow-error is detected as well: if the deflector grid fails to reach the requested position, an alarm is raised. Alarms are both visual and audible.
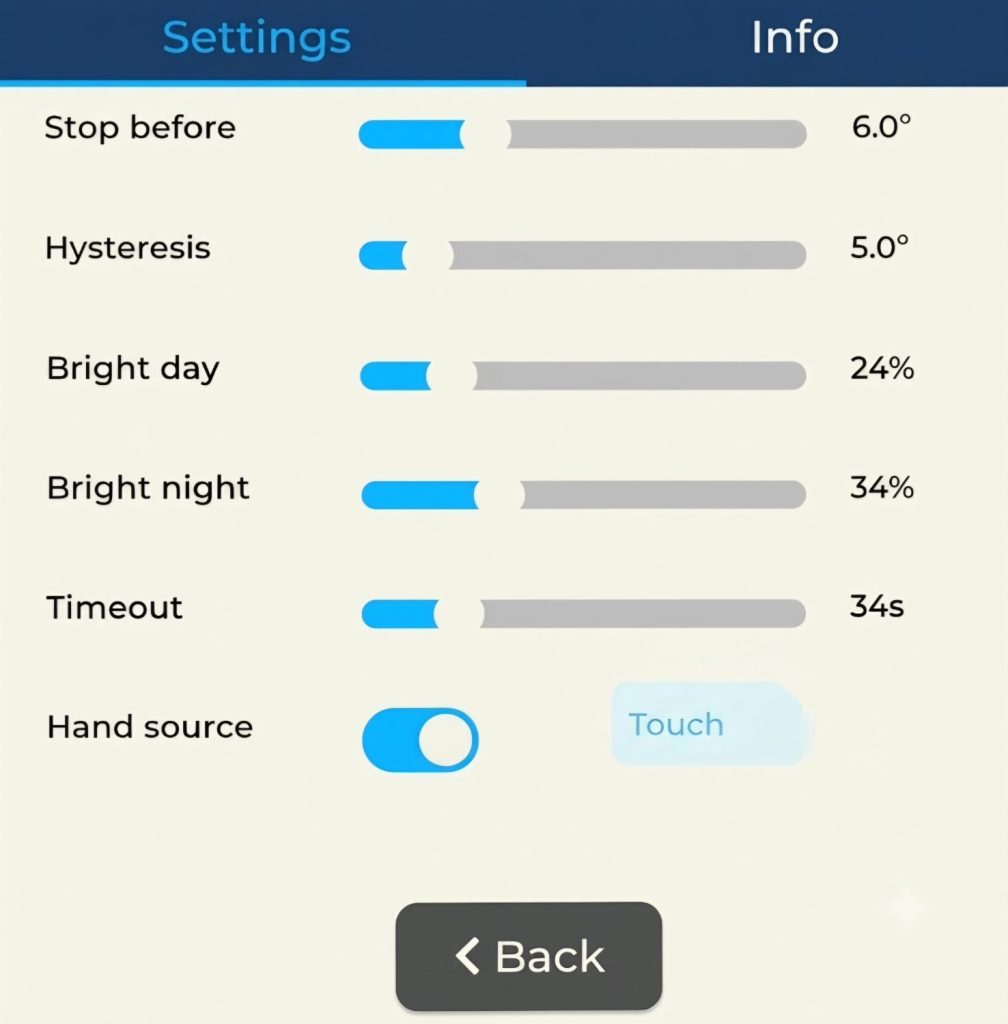
The software is developed entirely in C using ESP-IDF 5.x and FreeRTOS. The user interface runs on LVGL v8 with a day and night mode (separately dimmable), tailored to use on board a vessel. A hysteresis setting is also provided to prevent oscillation (hunting) of the steering system.
Technical specifications
| MCU | ESP32-S3 (240 MHz, dual-core) |
| Display | 480×480 px TFT |
| UI | LVGL v8 / ESP-IDF 5.3.5 |
| Bus | CAN / TWAI — 100 kbps |
| Power | 12..36VDC |
Gallery: